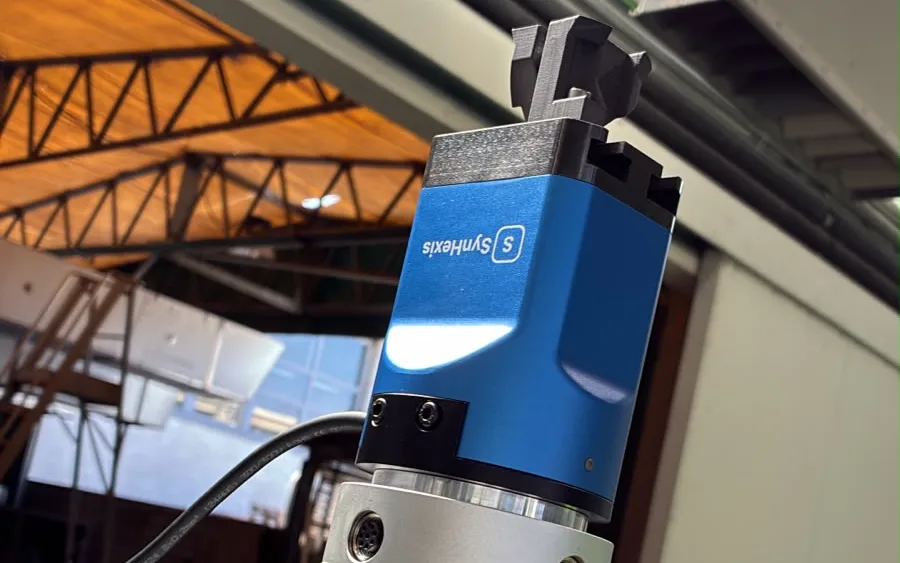
The gripper decides whether the cell works
A precise robot with the wrong grip drops parts, marks them or slows the cycle down. That is why we design our grippers ourselves, starting from the part: its shape, weight, material, surface and cycle time.
Catalogue electric grippers
They are electric, need no compressed air and are ready to connect to Fairino cobots.
Bespoke grippers
- Fingers shaped to the part and 3D printed, including in composite material.
- Vacuum grippers for cartons, sheets and flat parts.
- Multiple grippers to pick and place in a single cycle.
- Sensors for part presence and position.
Frequently asked questions
Which robots can SynHexis grippers be fitted to?
They are ready for Fairino cobots and, with the appropriate flange, can be fitted to any robot with an ISO 9409 flange.
Can you design a gripper for my part?
Yes, it is what we do every day. Send us the drawing or a few parts: we design the fingers or the entire gripper and test it before delivery.
Why 3D printed fingers?
Because they can be shaped precisely to the part, they are lightweight, they can be produced in a few days and they are easy to replace when the product changes.